Why is it the ideal choice of frameless torque motor for humanoid robots? Unlike traditional motors, frameless torque motors are compact and lightweight, offering greater design flexibility and higher torque density. They are specifically tailored to meet the demands of humanoid robot joints, providing rapid response, low friction, and high efficiency.

What Is a Frameless Torque Motor?
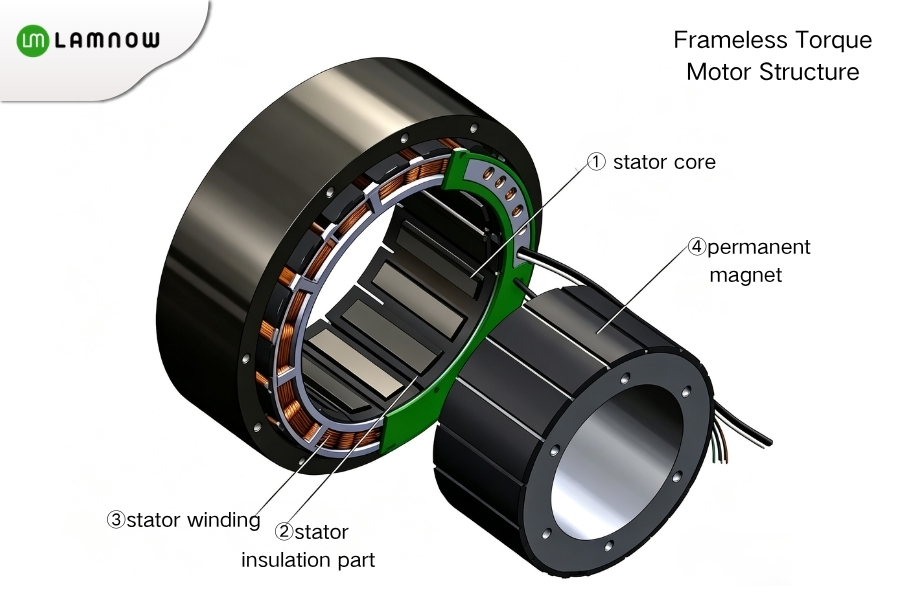
A frameless torque motor is a frameless permanent magnet brushless synchronous motor composed of two primary components:
Rotor: The internal component, consisting of a rotating steel ring embedded with permanent magnets. It is directly mounted onto the machine shaft.
Stator: The external component, featuring laminated silicon steel sheets and copper windings, generating electromagnetic force tightly integrated within the machine housing.
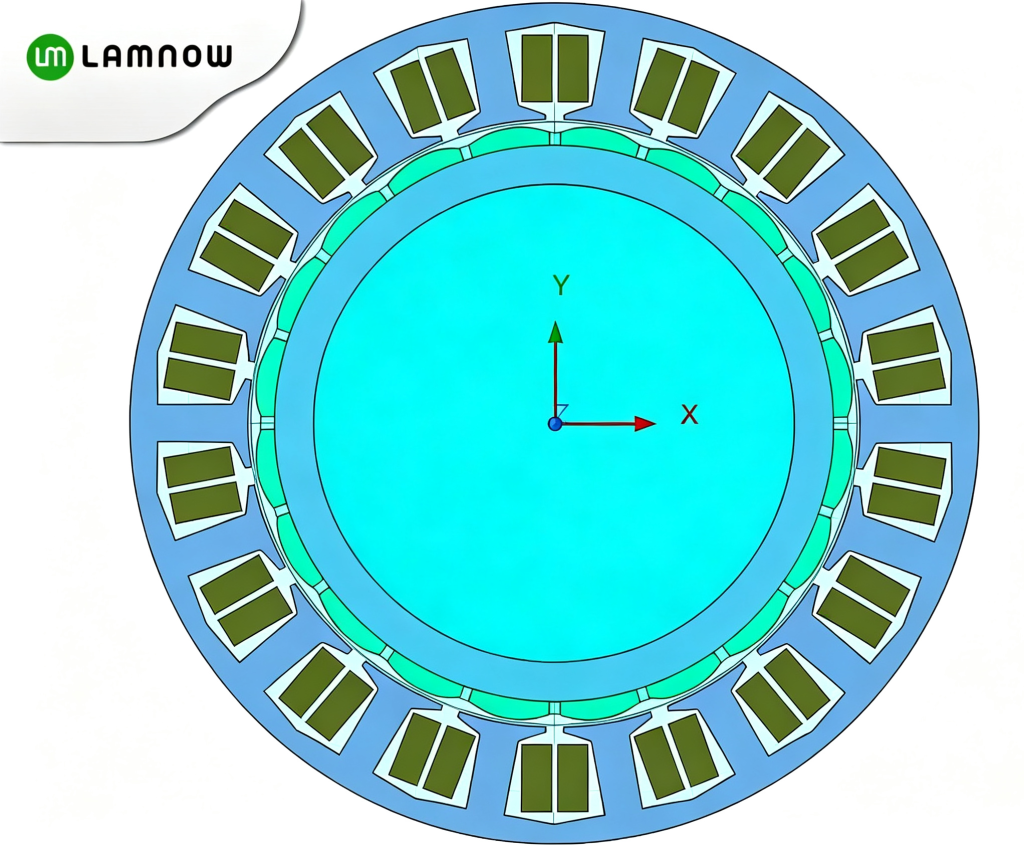
Now, we take the frameless torque motor (DC48V, 460W, rated torque 1.75N·m, rated speed 2500rpm) as an example to carry out electromagnetic simulation.
How to finite element simulation of the frameless torque motor using Maxwell
1.Model construction
2. Simulation Setup
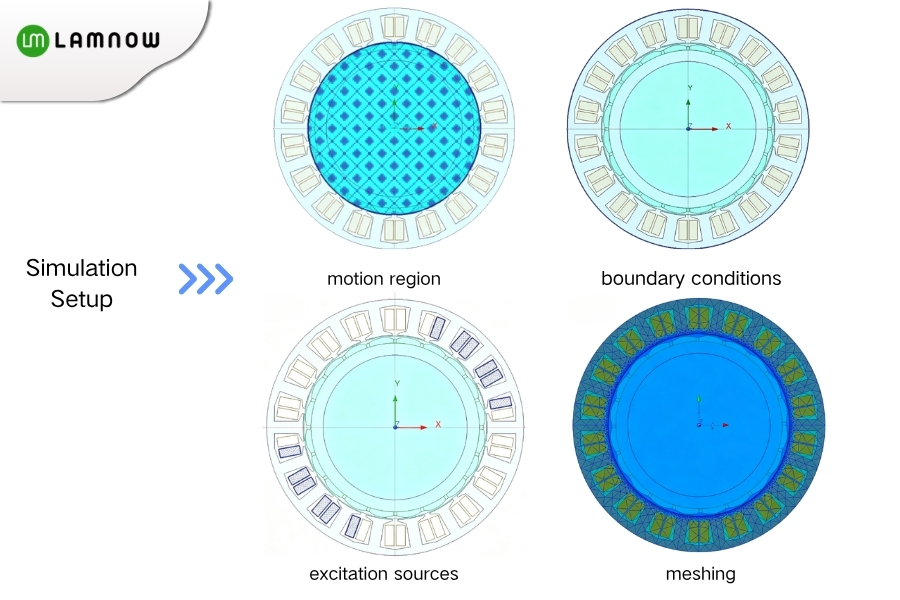
Define the motion region and boundary conditions, set up excitation sources, generate the mesh, and configure the solution steps.
3. No-load Simulation Characteristics
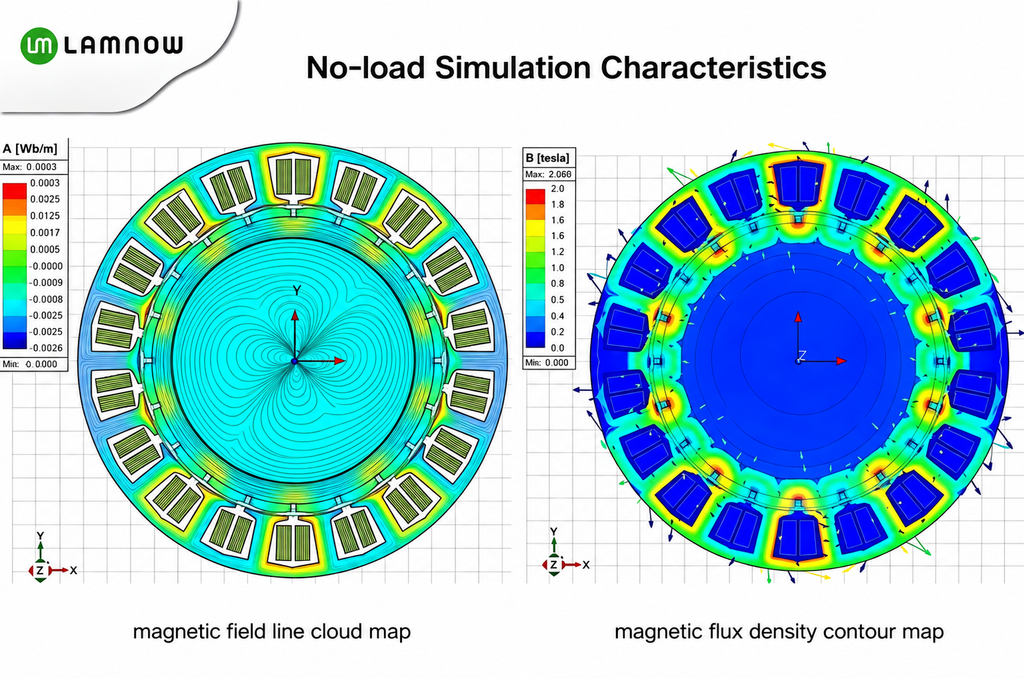
No-load simulation of frameless torque motors focuses on analyzing back-EMF waveforms, cogging torque, magnetic flux density distribution, and iron loss characteristics. Optimizing the pole-slot combination, air-gap magnetic flux density, and magnet structure can suppress torque ripple and enhance operational stability, thereby providing a theoretical basis for high-precision servo control.
| Parameters | Calculated value |
| Amplitude of magnetic flux density in the stator yoke at no-load | 1.4982T |
| Amplitude of magnetic flux density in the stator teeth at no-load | 1.5464T |
| Amplitude of air-gap magnetic flux density at no-load | 1.0651 |
| RMS value of no-load line back-EMF at 2500 rpm | 19.997V |
| RMS value of no-load line back-EMF at 1000 rpm | 8.3323V |
| Magnetic leakage coefficient | 1.08 |
| Phase inductance | 0.1529mH |
| Line inductance | 0.327mH |
| d-axis inductance | 0.1627mH |
| q-axis inductance | 0.1643mH |
| Peak cogging torque | 1.8332mN.m |
| Cogging torque ratio | 0.1% |
4.Rated Load Operation Simulation
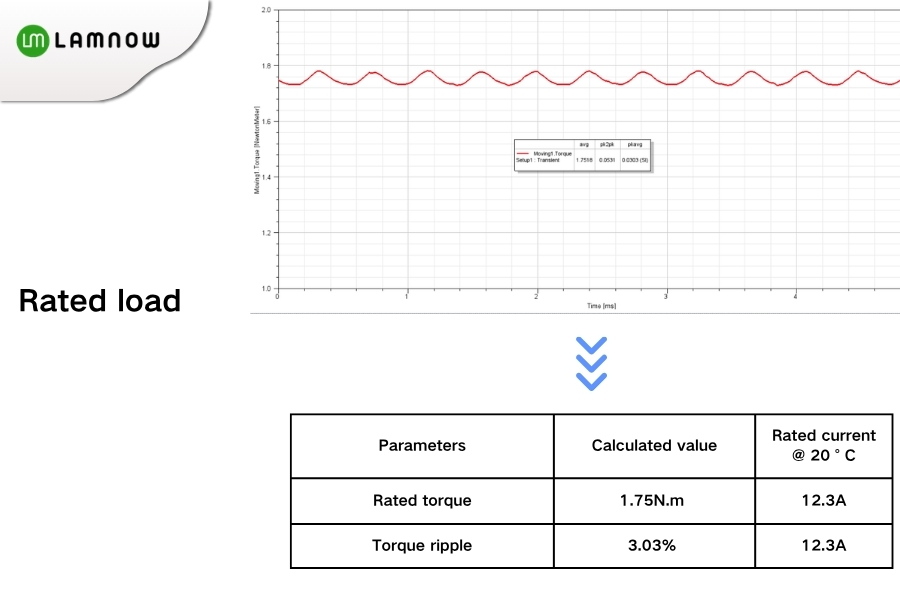
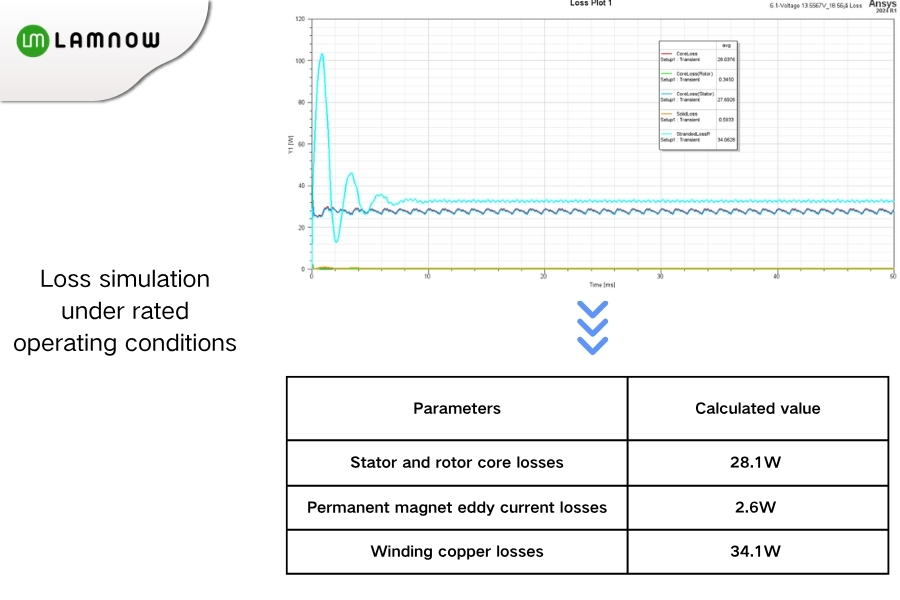
Electromagnetic simulation of the frameless torque motor under rated load is conducted to obtain the global magnetic flux density distribution and magnetic field vectors. The analysis verifies the magnetic saturation state, calculates rated output torque, torque ripple, and various losses, and evaluates the motor’s electromagnetic performance under rated operating conditions.
5. Overload Capability Analysis
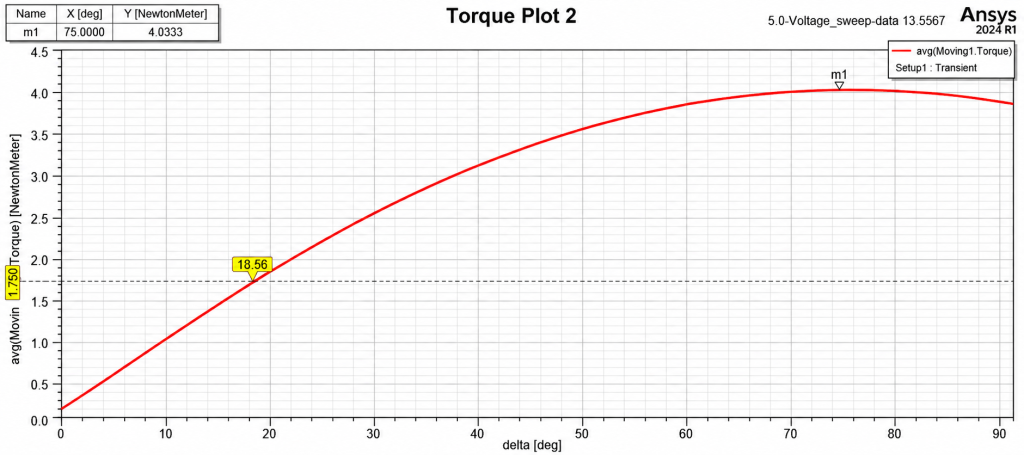
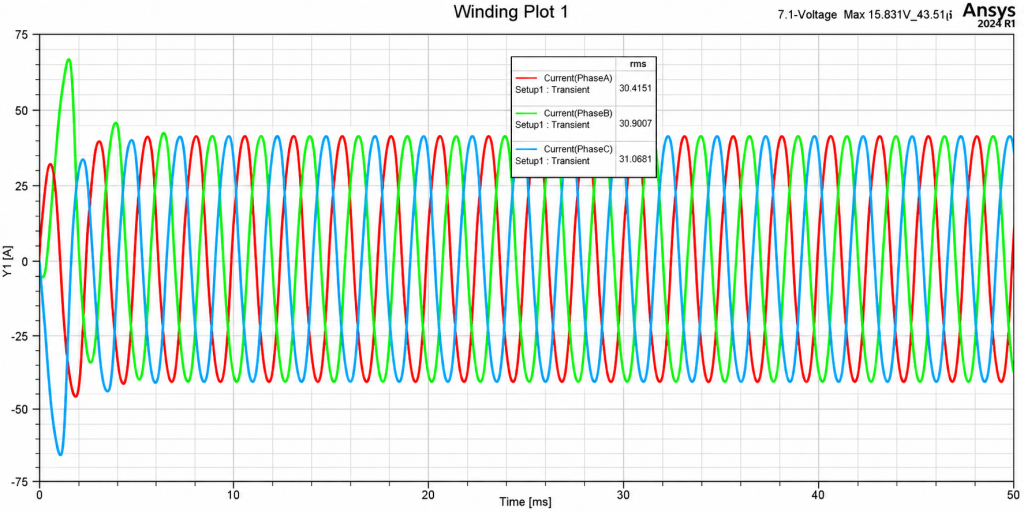
Overload capability reflects the motor’s short-term peak performance and is crucial for the explosive movements of humanoid robots.
| Parameters | Maximum torque | Maximum current |
| 2400RPM | 4N.m | 30.5A |
6. Anti-demagnetization simulation assessment
Permanent magnets may undergo irreversible demagnetization in high-temperature environments.
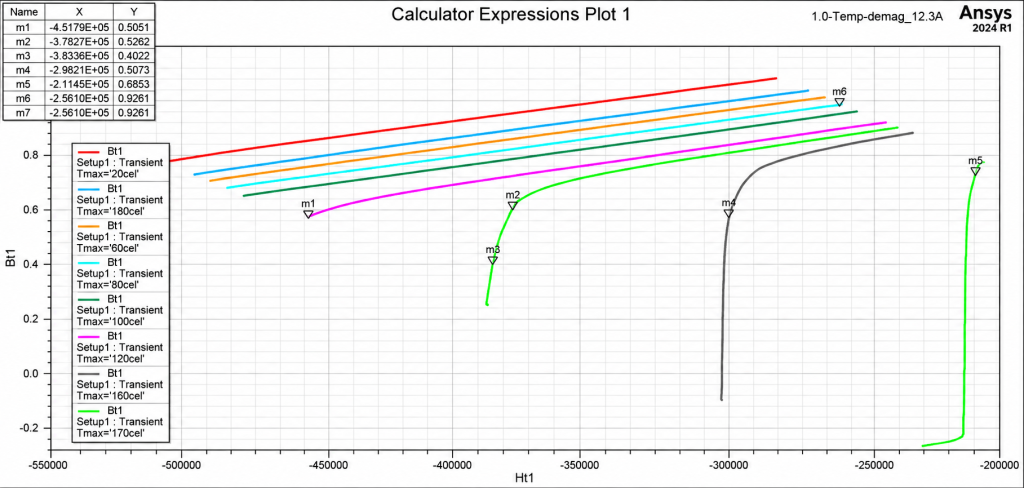
The results show that:
- A demagnetization knee point appears when the temperature reaches 150°C;
- The knee point becomes more pronounced at 160°C and 170°C;
- Almost complete demagnetization occurs when the temperature reaches 180°C.
7. Efficiency Simulation
Efficiency is a key indicator for measuring a motor’s energy conversion capability. Obtain efficiency, voltage, current, and loss maps through simulation to comprehensively evaluate the motor’s energy efficiency characteristics.
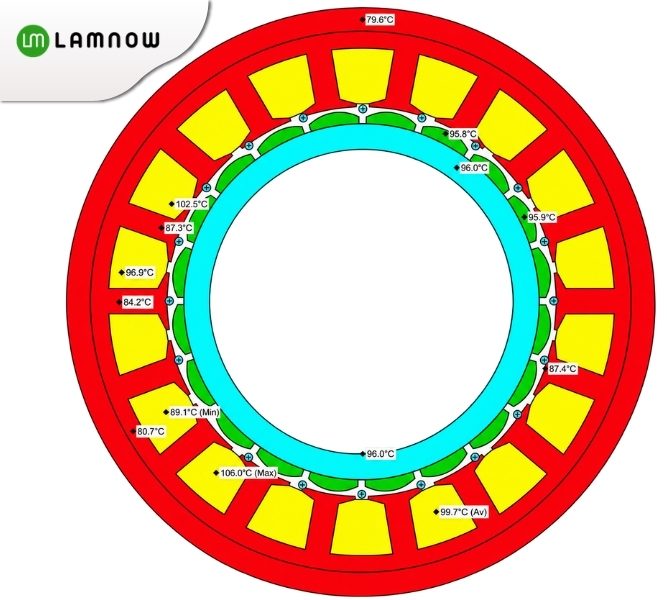
8. Thermal Simulation
Temperature rise limits a motor’s continuous operating capability; thermal management is key to high-performance motors.
9. Electromagnetic Force Waves and NVH Simulation
NVH characteristics affect the operational smoothness of the robot and the user experience.
What are the 9 key technical fields covering no-load to rated load, overload and demagnetization, efficiency, thermal management and NVH for frameless torque motors, and how is their current market situation?
Current Market for Frameless Torque Motors
The frameless torque motor market is currently small but growing rapidly. According to Technavio, the global torque motor market grew 6.95% in 2023, reaching $657 million. As humanoid robots become commercially viable, this growth is expected to accelerate.

While international companies like Kollmorgen, AVS Mechatronics GmbH, Maxon Motor, TQ Robodrive, Aerotech, and Allied Motion dominate the market with their expertise and advanced technology, Chinese companies are quickly catching up.
Companies such as Leadshine Technology, Estun Automation, Haozhi Mechanical, and Leadshine Intelligent have significantly narrowed the performance gap with international competitors.
For instance, comparing Kollmorgen and Leadshine, the output torque difference for motors of the same size is minimal, indicating rapid progress in China’s torque density advancements.
What Other Motors Are Used in Humanoid Robot?
| Motor | Characteristic | Application |
| Servo Motor | High-precision closed-loop control (encoder feedback) with ±0.01° positioning accuracy. Fast dynamic response (acceleration time <10ms), suitable for quick start-stop applications. Integrated with gear reducers (e.g., harmonic reducers) for high torque output. | High-precision joints (e.g., wrist and finger joints). |
| Coreless Motor | Iron-core-free rotor, using a coil with no internal support structure, typically under 40mm in size. Small size, high control accuracy, long lifespan, fast rotation, high efficiency, and high energy density. Compared to iron-core motors, they are 1/3 to 1/2 lighter and smaller while maintaining the same power output. | Finger joints |
Stepper Motor | Open-loop control, low cost, and simple structure. High torque at low speeds, but prone to step loss (requires a closed-loop driver for improvement). Positioning accuracy depends on step angle (e.g., 1.8° per step). | Low-cost joints or auxiliary drives (e.g., head rotation) |
| BLDC Motor (brushless dc motor) | High efficiency (>90%) and long lifespan (no brush wear). High-speed operation (>10,000 RPM), suitable for high-speed joints or wheeled drives. Requires an electronic speed controller (ESC) for precise control. | Mobile platform drive wheels, high-speed rotary joints. |
| Linear Motor | Direct linear motion, eliminating the need for mechanical transmission (e.g., lead screws). Ultra-high acceleration (>10g) and ±1μm positioning accuracy. High cost, making them suitable for precision positioning applications. | Precision assembly, high-accuracy linear joints. |
With strong governmental support for private enterprises and emerging production forces, along with the rapid development of AI-driven robotics, humanoid robots are poised for explosive growth. The industry is currently at a stage similar to electric vehicles in 2014, on the brink of mass production and entering a decade-long industrial boom.
Custom Robot Motor Stator and Rotor – Choose Lamnow
Lamnow designs and manufactures robotic motor lamination in China. Our laminations include coreless motor lamination, torque motor stator and rotor, servo motor lamination, stepper motor stator and rotor lamination, and permanent magnet synchronous motor lamination core. If you need robotic motor core, please contact us.